EMMA: Scaling Mobile Manipulation via Egocentric Human Data

IEEE Robotics and Automation Letters (RA-L) 2026
ICRA 2026 · Oral Presentation
Georgia Institute of Technology

*,† equal contributions

Abstract

Scaling mobile manipulation imitation learning is bottlenecked by expensive mobile robot teleoperation. We present Egocentric Mobile Manipulation (EMMA), an end-to-end framework training mobile manipulation policies from human mobile manipulation data with static robot data, sidestepping mobile teleoperation. To accomplish this, we co-train the human full-body motion data with the static robot data. In our experiments across three real-world tasks, EMMA demonstrates comparable performance to baselines trained on teleoperated mobile robot data (Mobile ALOHA), achieving higher or equivalent task performance in full task success with significantly less data. We find that EMMA is able to generalize to new spatial configurations and scenes, and we observe positive performance scaling as we increase the hours of human data, opening new avenues for scalable robotic learning in real-world environments.

Video

Method

A unified co-training framework

EMMA co-trains human full-body motion data with static robot data and outputs a unified policy that enables mobile manipulation deployment without mobile robot teleoperation.
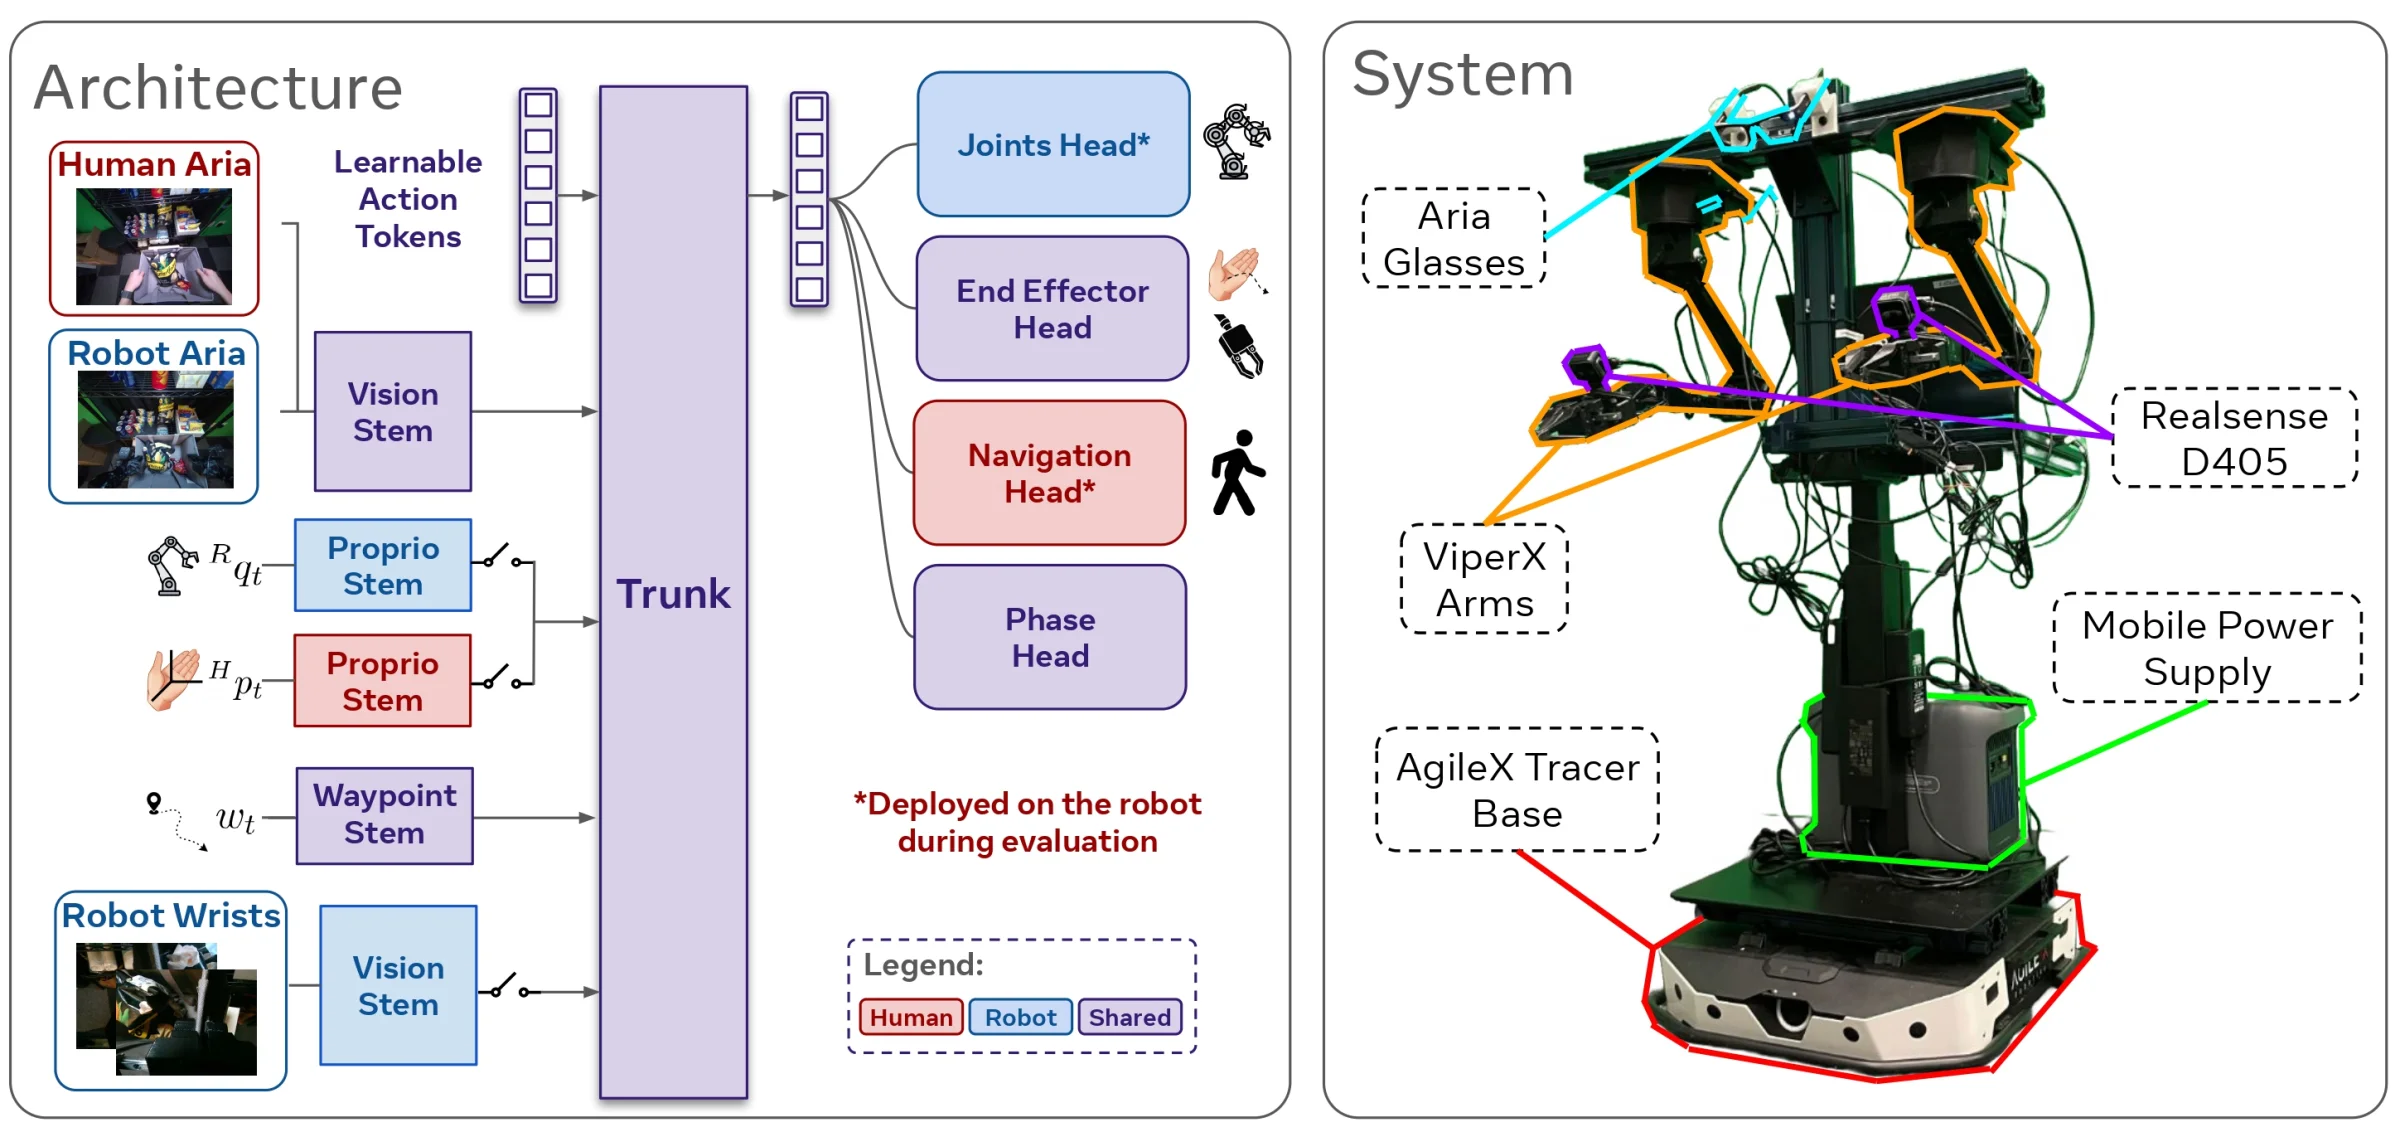
EMMA architecture: human and robot data are processed by separate stems, a shared trunk, and multiple action heads including a navigation head; right, the custom low-cost bimanual mobile manipulator.
Left: Architecture of joint human-robot policy learning framework. Our model processes heterogeneous human and robot data through stems and decodes them through various action heads. The navigation head is deployed on the robot during evaluation, demonstrating transfer without robot supervision. Right: Our custom low-cost bimanual mobile manipulator.

Retargeting

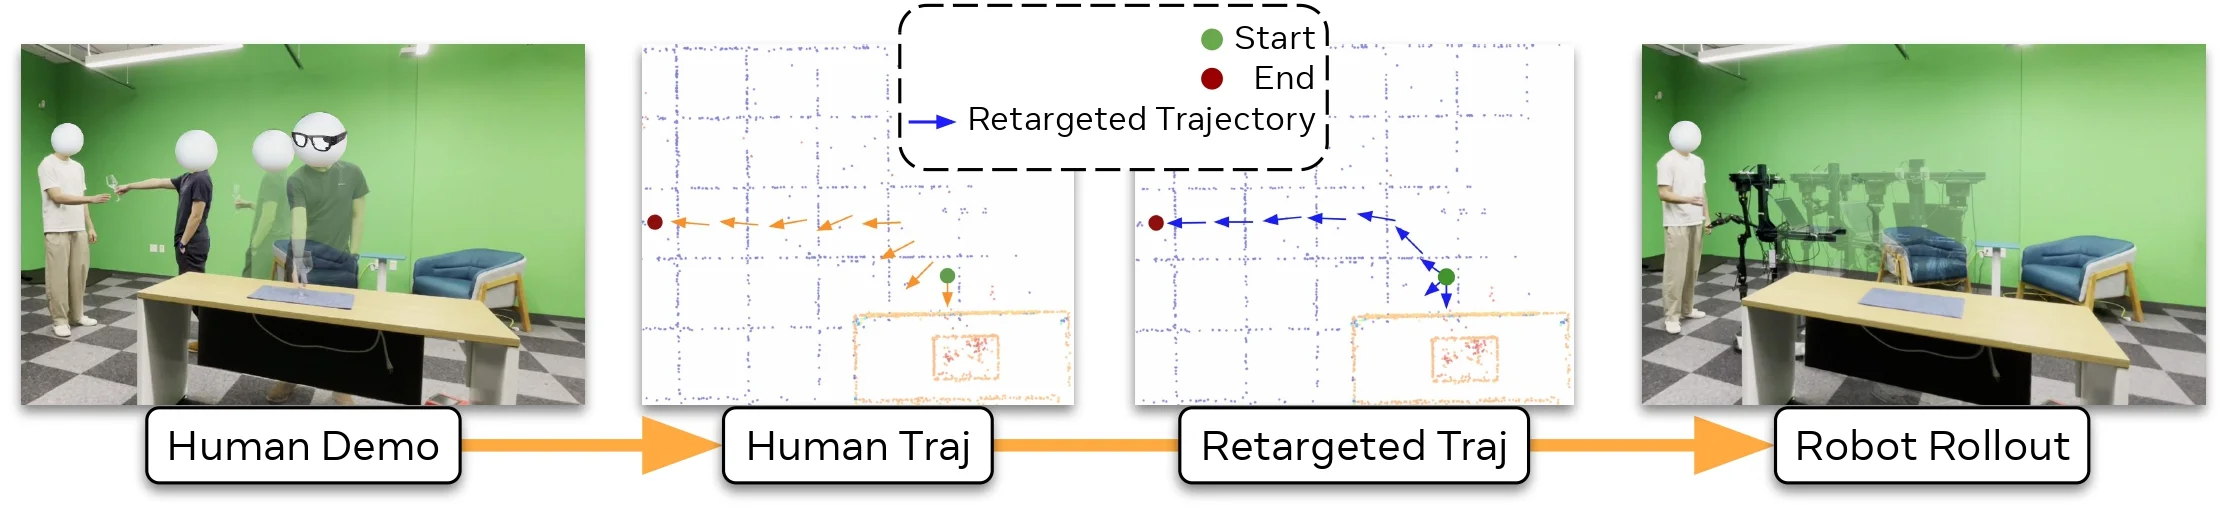
Retargeting a human 3D pose trajectory into a feasible 2D trajectory for a differential-drive robot.
Given a 3D pose trajectory from a human demonstration, we compute a feasible 2D trajectory for a differential drive robot. This resulting trajectory can be directly executed by the robot or used as input for policy learning.

Results

(A) In-domain Performance

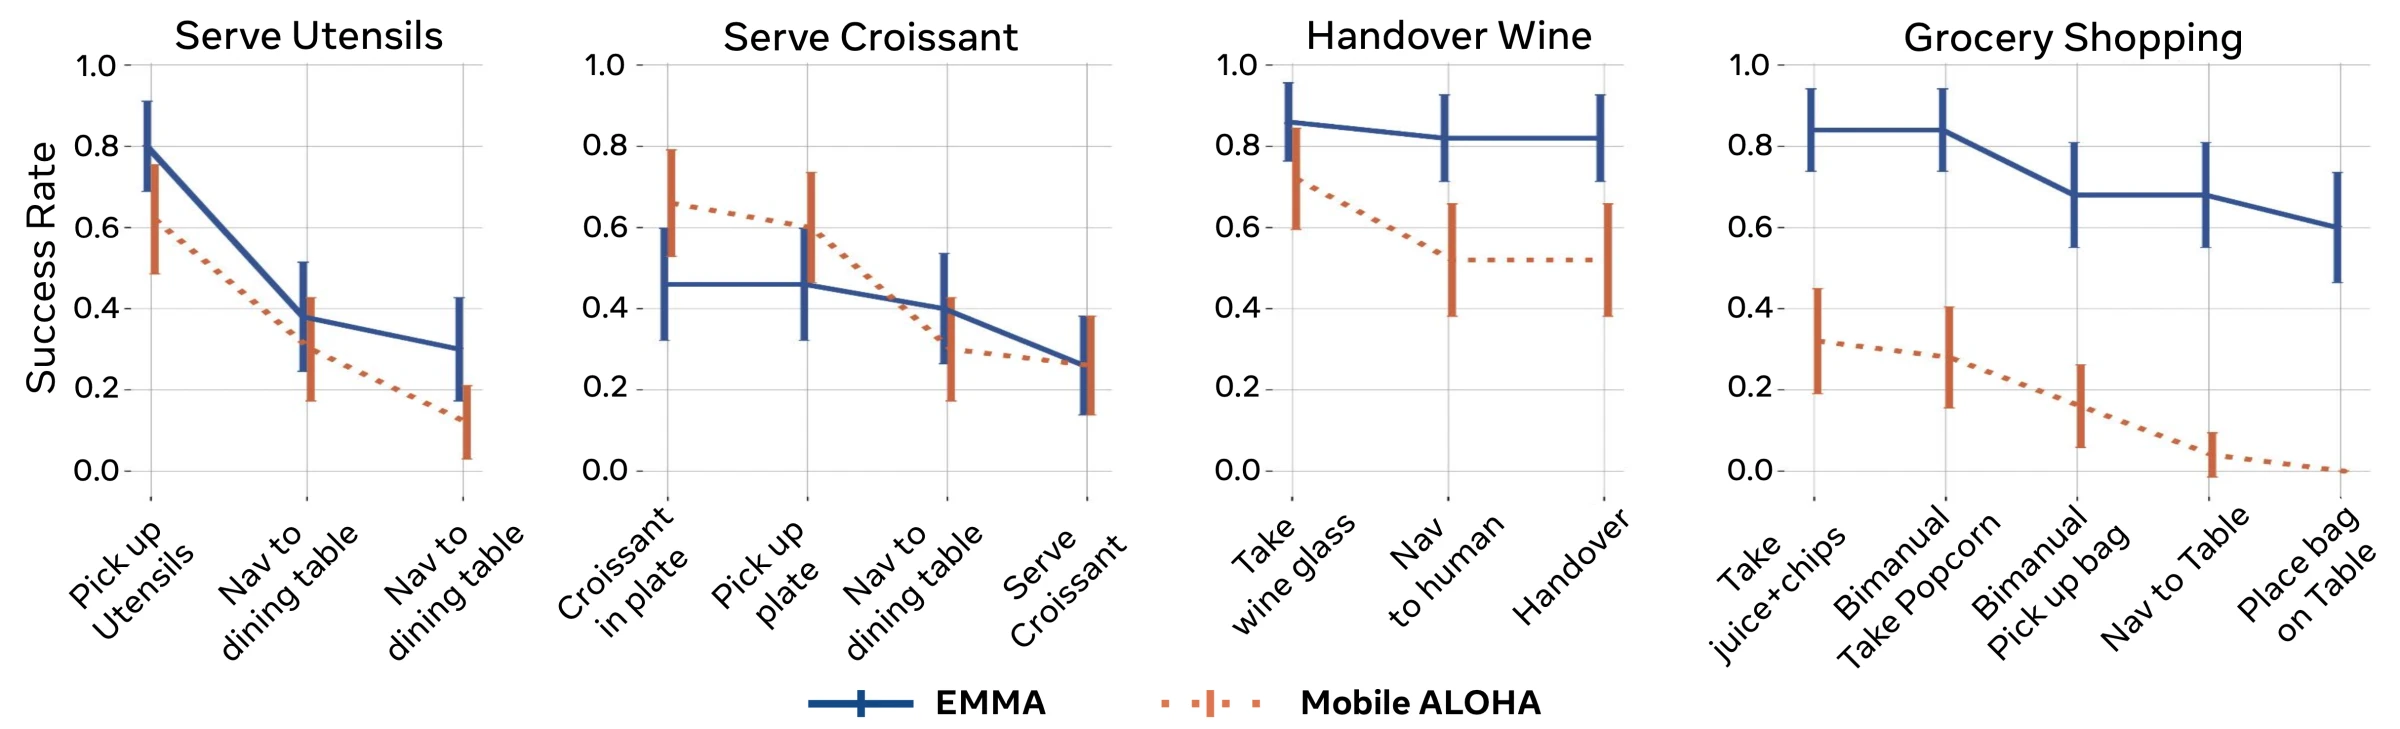
Bar charts of subtask success rates for EMMA versus Mobile ALOHA on Grocery Shopping, Handover Wine, and Table Service tasks.
EMMA (blue), trained without mobile teleoperation data, significantly outperforms Mobile ALOHA (orange) on Grocery Shopping and Handover Wine tasks (p < 0.05). Table Service variants show comparable performance. Error bars represent 95% confidence intervals from 50 trials.

(B) Scene Generalization

EMMA generalizes to new scenes by co-training on static robot data in the original scene and human full-body motion data in the new scene.

(C) Scaling

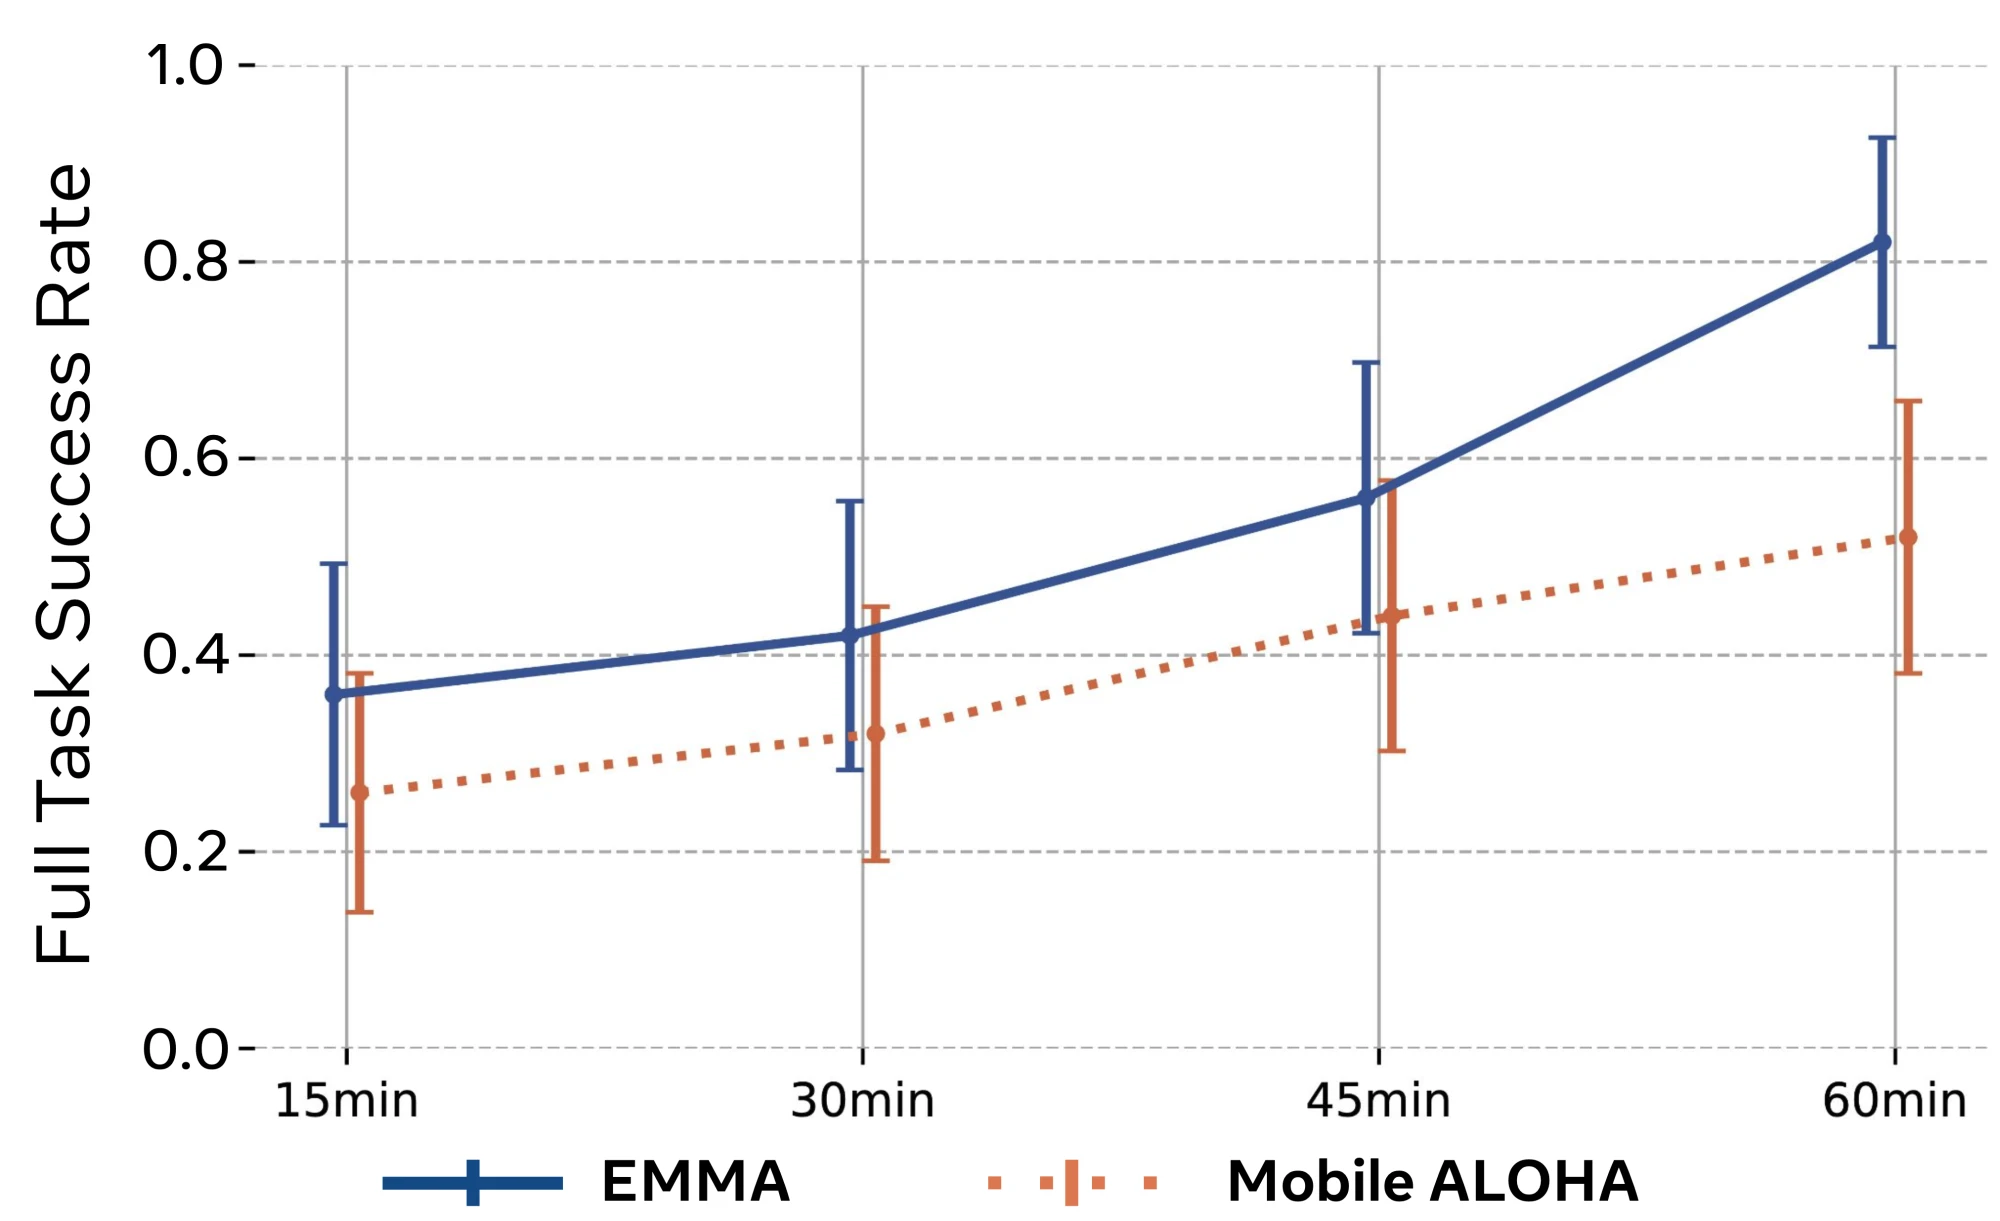
Scaling human full-body motion data vs. scaling mobile robot teleop data

Task success versus hours of data: EMMA scaling human full-body motion data compared with Mobile ALOHA scaling mobile robot teleoperation data on Handover Wine.
EMMA trained on 1 hour of human full-body motion data (blue) strongly outperforms Mobile ALOHA trained on 1 hour of robot data (orange) in the Handover Wine task. We show that scaling mobile manipulation with human data outperforms scaling on mobile robot teleoperation data collected under an equivalent amount of time.

Conclusion

In conclusion, we presented EMMA, a novel framework that enables mobile manipulation without requiring expensive mobile teleoperation. We find that EMMA outperforms Mobile ALOHA style teleoperation with equivalent data collection time and demonstrates superior scaling properties. Further, we ablate our key design decisions and observe that both the motion retargeter and the phase identification module are integral to downstream performance. Overall, we have demonstrated the possibility of scaling robot mobile manipulation performance with egocentric human data. We hope this result spurs new research and informs future researchers of potential opportunities and challenges.

BibTeX

@article{zhu2026emma,
  title={{EMMA}: Scaling Mobile Manipulation via Egocentric Human Data},
  author={Zhu, Lawrence Y and Kuppili, Pranav and Punamiya, Ryan and Aphiwetsa, Patcharapong and Patel, Dhruv and Kareer, Simar and Ha, Sehoon and Xu, Danfei},
  journal={IEEE Robotics and Automation Letters},
  year={2026},
  publisher={IEEE},
  note={Presented at ICRA 2026}
}